Products — Quadrupeds
Four legs. One hard problem.
Why legs
The most honest teaching platform in robotics.
A wheeled robot forgives a lot. A legged one does not. It has to sense its own state, decide continuously, and commit to each step — and when the maths is wrong, it lands on the floor in front of you.
That immediacy is why quadrupeds make such good platforms to learn on. The whole stack — actuation, sensing, control and software — has to work at once, and you find out straight away which part does not.
What you work on
One machine, the whole stack.
Locomotion
Gaits, footfall timing and the mechanics of moving a body on legs rather than wheels.
Control
Feedback loops that keep a machine upright while the ground refuses to cooperate.
Sensors
Encoders, inertial measurement and the business of knowing where the robot actually is.
Embedded systems
Timing, communication and driving a dozen actuators without falling behind.
Robotics software
Structuring code that has to run continuously on a machine that can fall over.
Autonomy
Deciding where to put the next foot without anyone holding the controller.
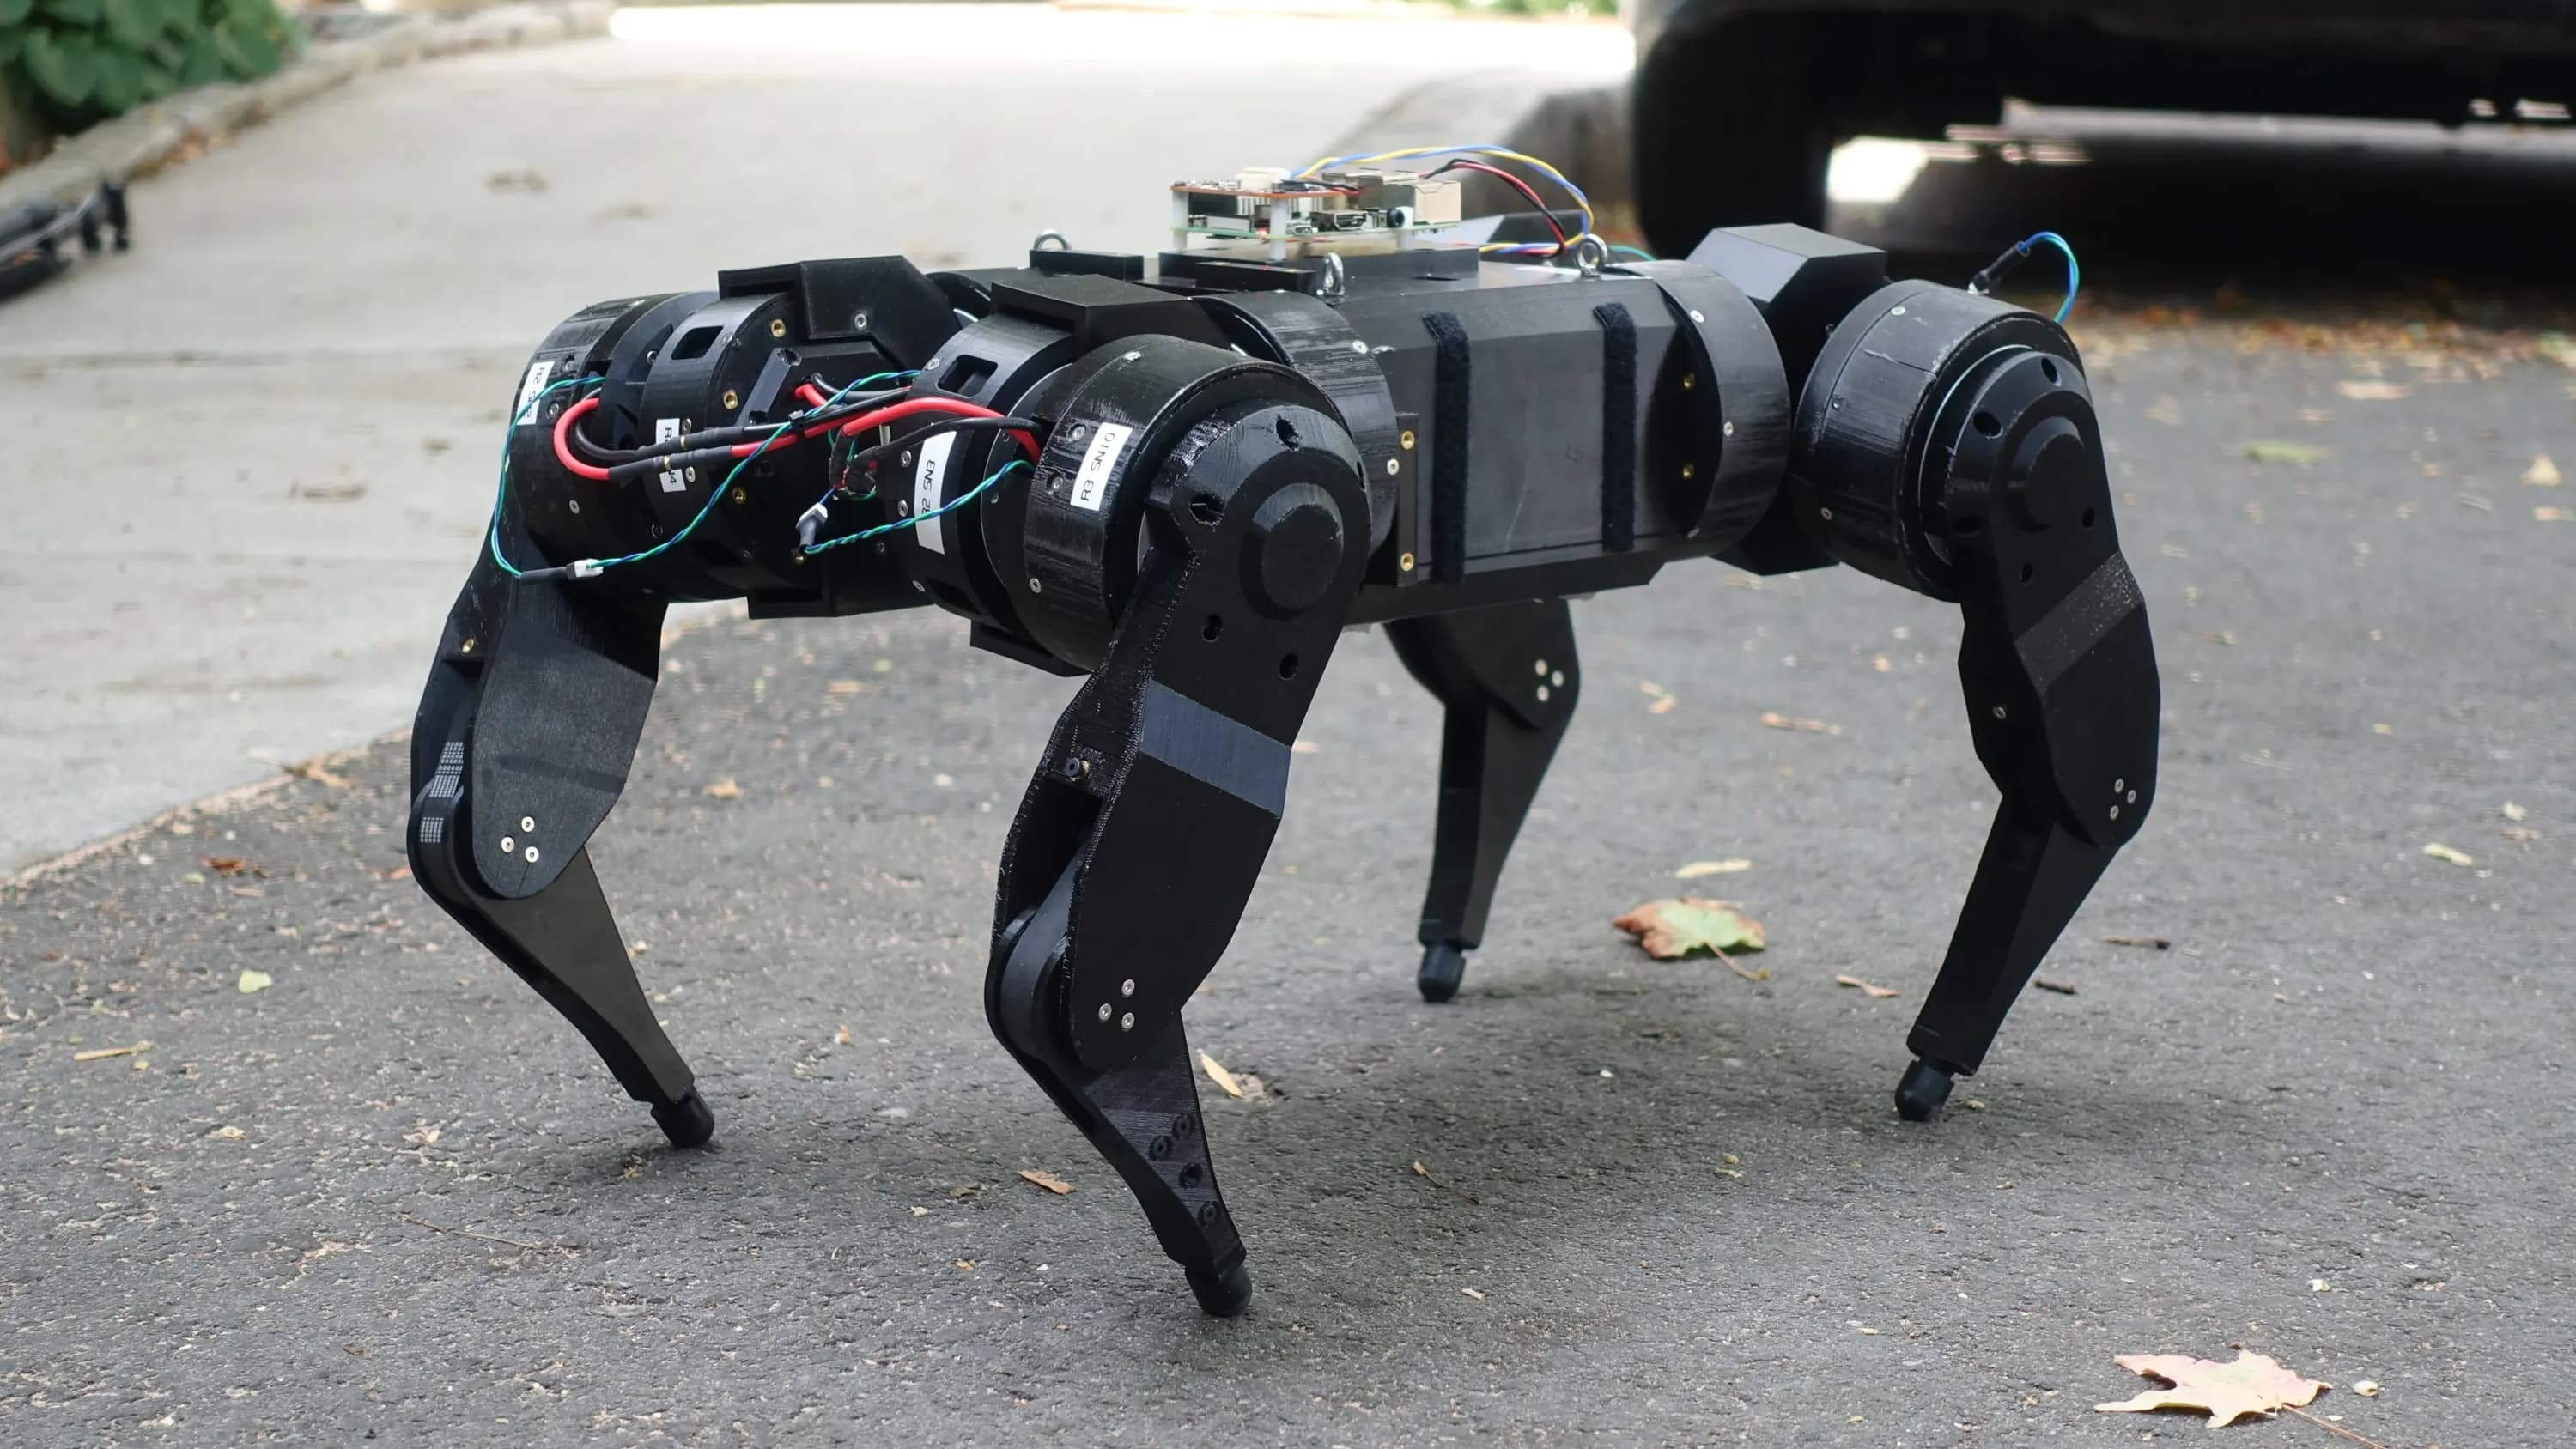
Actuators, linkages and wiring — exposed by design
Working with one
A platform you keep developing against.
Specific configurations and availability are confirmed case by case, because what a quadruped needs to be depends entirely on what you intend to do with it. Tell us what you are working on — a course, a research problem, a personal build — and we will be straightforward about what we can supply and support.
Quadrupeds